7 Tips for Choosing an MCB Assembly Robot?
Choosing an MCB Assembly Robot is not just a matter of comparing cycle times. A machine may look impressive in a brochure, yet struggle with tiny component variations on a busy production floor. The right choice depends on the breaker design, target output, changeover frequency, and available maintenance support. Small details matter: a feeder that jams, a gripper that marks a plastic housing, or a sensor that misses a misaligned part can interrupt an entire shift.
A credible evaluation should begin with real production samples and a clear acceptance test. Ask vendors to demonstrate assembly using your components, then inspect placement accuracy, reject handling, traceability, and recovery after a fault. Automation specialist Dr. Elena Morris offers a useful reminder: “A robot earns its place when it delivers repeatable quality, not just a fast cycle time.” Treat that as a practical selection principle, not a substitute for verified performance data. Confirm the machine’s claims through documented trials and reference installations.
The seven tips ahead examine these decisions, from tooling flexibility to operator training and after-sales service. They also challenge an easy assumption: the highest-speed system is not always the best investment. A slower line may prove more dependable when products change often or technicians are scarce. There is no perfect setup. The goal is a Mcb Assembly Robot that fits your actual products, people, and production targets—and can keep doing so after the showroom demonstration ends.
Define MCB Requirements Using IEC 60898-1 Ratings Up to 125 A
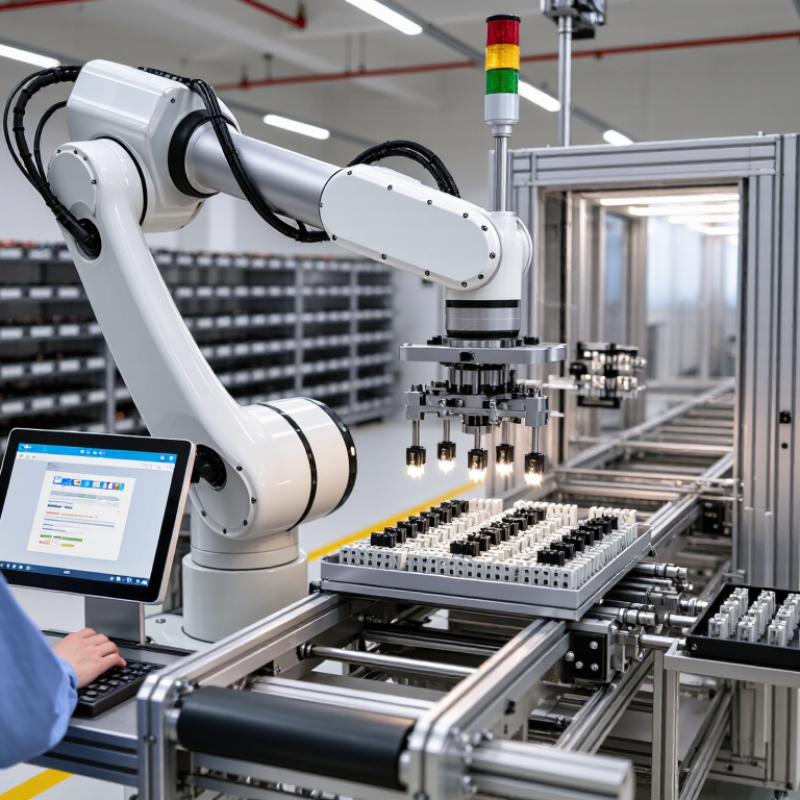
Choosing an MCB assembly robot starts with the circuit breaker, not the machine. IEC 60898-1 defines key requirements for household and similar AC applications, including ratings up to 125 A. Record rated current, voltage, pole configuration, tripping curve, and short-circuit capacity. Small details matter. Tip 1: Confirm every product variant. Tip 2: Separate electrical requirements from assembly preferences.
Tip 3: Select a robot that handles the largest MCB housing without unstable gripping. Tip 4: Check insertion force, terminal alignment, screw torque, and contact positioning. These operations need repeatable motion, not only high speed. Tip 5: Integrate testing for continuity, insulation, and mechanical operation. A robot may assemble perfectly and still miss a weak contact. IEC 60898-1 ratings should guide the test limits, while qualified engineers verify the final values.
Tip 6: Match the vision system to real defects, such as reversed components, damaged terminals, or incomplete springs. Tip 7: Review changeover time for ratings from low current values through 125 A. Different housings can expose poor fixture design quickly. In my experience, a flexible cell often beats a faster dedicated machine when product versions change. That is not always true. Production volume and tolerance data must decide. Ask for traceability, torque records, alarm history, and sample-run evidence before approval. Also inspect operator access and maintenance points. An impressive demonstration can hide difficult cleaning, awkward loading, or unreliable sensors. Fancy is not proof.
7 Tips for Choosing an MCB Assembly Robot? - Define MCB Requirements Using IEC 60898-1 Ratings Up to 125 A
| Tip | Requirement to Define | Example Data or Range | Implication for Robot Selection | Suggested Verification |
|---|---|---|---|---|
| 1. Confirm the applicable standard and product scope | Identify the MCB’s intended application and the applicable edition or national adoption of IEC 60898-1. | IEC 60898-1 covers air-break circuit-breakers for overcurrent protection in household and similar installations, within its stated AC voltage, current and short-circuit-capacity limits. | Use the actual product drawing, bill of materials and approved process requirements as robot inputs; the standard itself does not prescribe a particular assembly robot. | Check the product specification and compliance plan with the manufacturer’s engineering or quality team. |
| 2. Set rated current and product variants | Define the rated-current range, variant mix and changeover frequency. | For products within the title’s scope, rated current is up to 125 A. Example product variants may include 6 A, 10 A, 16 A, 20 A, 32 A, 40 A, 63 A, 80 A and 100 A; confirm the actual approved ratings for the product family. | Choose feeders, part presentation and recipe control to accommodate the required variant mix while preventing components from being loaded into the wrong product configuration. | Run a recipe-change test and verify component identity against the work order or product code. |
| 3. Specify voltage, poles and terminal configuration | Record rated voltage, pole arrangement, terminal style and the dimensions that differ between variants. | Depending on the product design, pole arrangements can include 1P, 1P+N, 2P, 3P, 3P+N or 4P. These are examples, not a universal product requirement. | Confirm gripper access, orientation, fixture spacing and whether separate tooling or robot programs are needed for different pole counts and terminal designs. | Test representative minimum- and maximum-size configurations, including terminal and enclosure clearances. |
| 4. Define the breaking-capacity and mechanism variants | Specify the rated short-circuit capacity and any mechanism, contact or arc-chute differences by model. | IEC 60898-1’s scope includes rated short-circuit capacities up to 25 kA. The value for a particular MCB must come from its approved rating and product documentation. | Design assembly and inspection steps around the actual components and process controls; do not infer breaking capacity from appearance or rated current alone. | Use part verification and traceable process records. Electrical performance testing should follow the approved test plan and applicable standard requirements. |
| 5. Match the robot to the assembly operations | List each operation, such as component loading, mechanism assembly, screwdriving, marking or final handling. | For each step, define part mass, position tolerance, insertion direction, fastening parameters and required cycle time from process trials. | Select robot reach, payload, repeatability, end-of-arm tooling and axis count based on the real operation and fixture layout—not on rated current alone. | Conduct a process-capability trial at the required production rate and check for missed, reversed or incorrectly seated parts. |
| 6. Build in quality checks and traceability | Identify critical-to-quality features and the records needed for each unit or batch. | Possible checks include component presence and orientation, fastener completion, marking or code readability, and dimensional or functional checks specified by the control plan. | Integrate suitable sensors, vision systems, torque monitoring and data handling where justified by the process risk and quality plan. | Challenge the inspection system with known good and deliberately incorrect samples; verify that reject handling and records work as intended. |
| 7. Plan safety, changeover and maintainability | Define operator access, safeguarding, expected uptime, maintenance access and future product changes. | Set measurable targets for changeover time, planned maintenance, spare tooling and production availability based on the factory’s operating requirements. | Compare cell layouts, guarding, interlocks, service access and modular tooling. Include the expected product variants and production volume in the evaluation. | Review the risk assessment, validate safeguarding functions, and perform a maintenance and changeover acceptance test before production release. |
Note: The example ratings and configurations are illustrative. Confirm the applicable standard edition, product ratings, tolerances and inspection requirements against the specific MCB’s approved technical documentation.